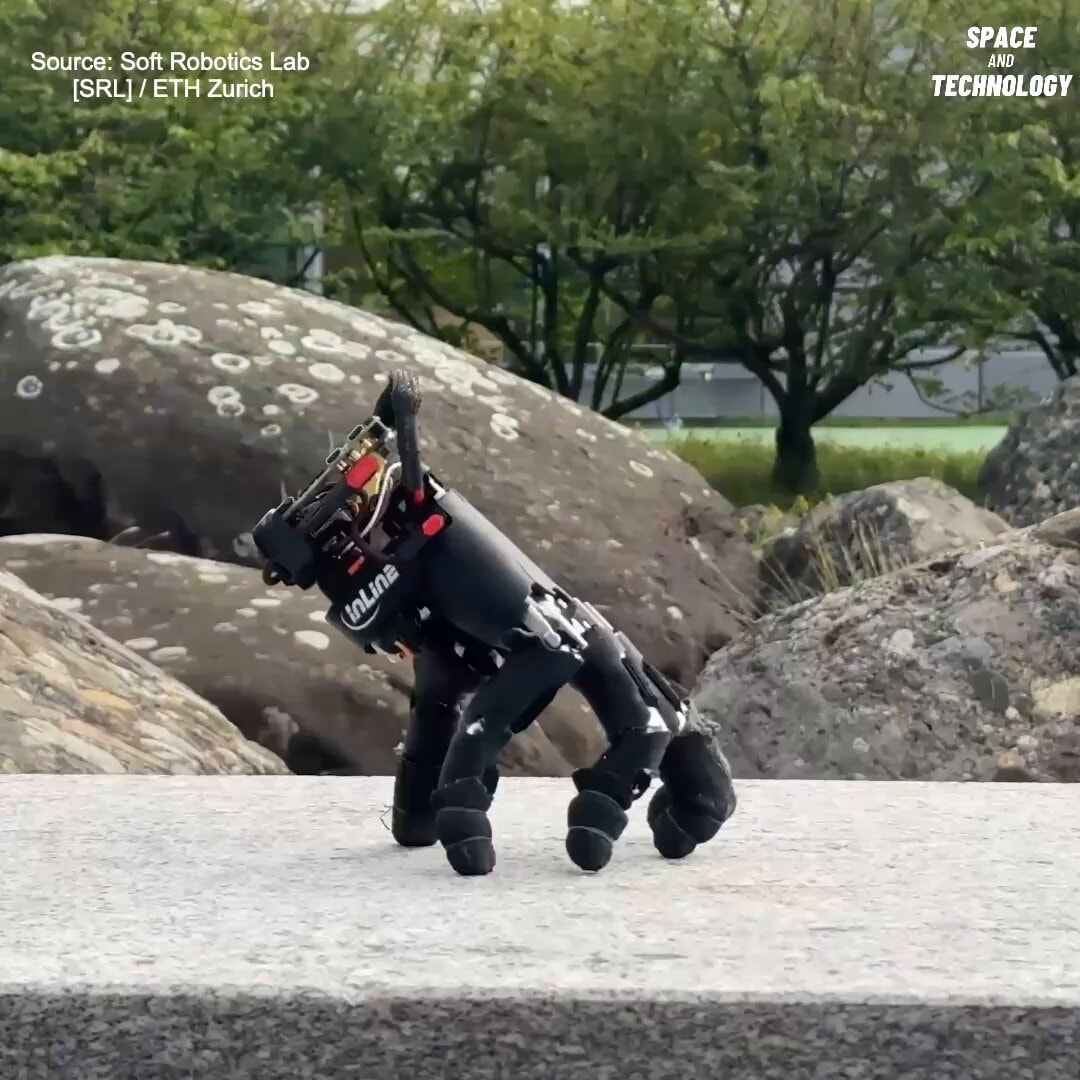
ETH Zurich robotic hand walks on fingers
por Terrymiller: ETH Zurich
A robotic hand out of ETH Zurich's Soft Robotics Lab that ditches wheels entirely and walks on its own five fingers. The whole rig runs untethered because power, sensing and computation are all packed onboard. Reinforcement-learning policies drive the movement, letting it crawl, steer, climb back up after a tumble, and shift its gait to match the ground underneath. That ground game covers 14 surfaces, indoor and outdoor, from tile and carpet to grass, gravel and asphalt. It can also bear its own weight while tapping keys on a keyboard, and overhead visual feedback lets it nudge objects toward set targets. The arm is marked inLine, and the build comes from Soft Robotics Lab [SRL] / ETH Zurich. #ETHZurich
Transcrição (en)
Researchers at ETH Zurich have taught a robotic hand to walk using its fingers as legs. The hand carries its own battery and computer, allowing it to move without a tether. Using reinforcement learning, researchers trained it to crawl, steer, and recover after falling. It successfully moved across 14 different surfaces, including carpet, tile, asphalt, grass, and gravel. The hand can also press keyboard keys while supporting itself and push objects toward targets.