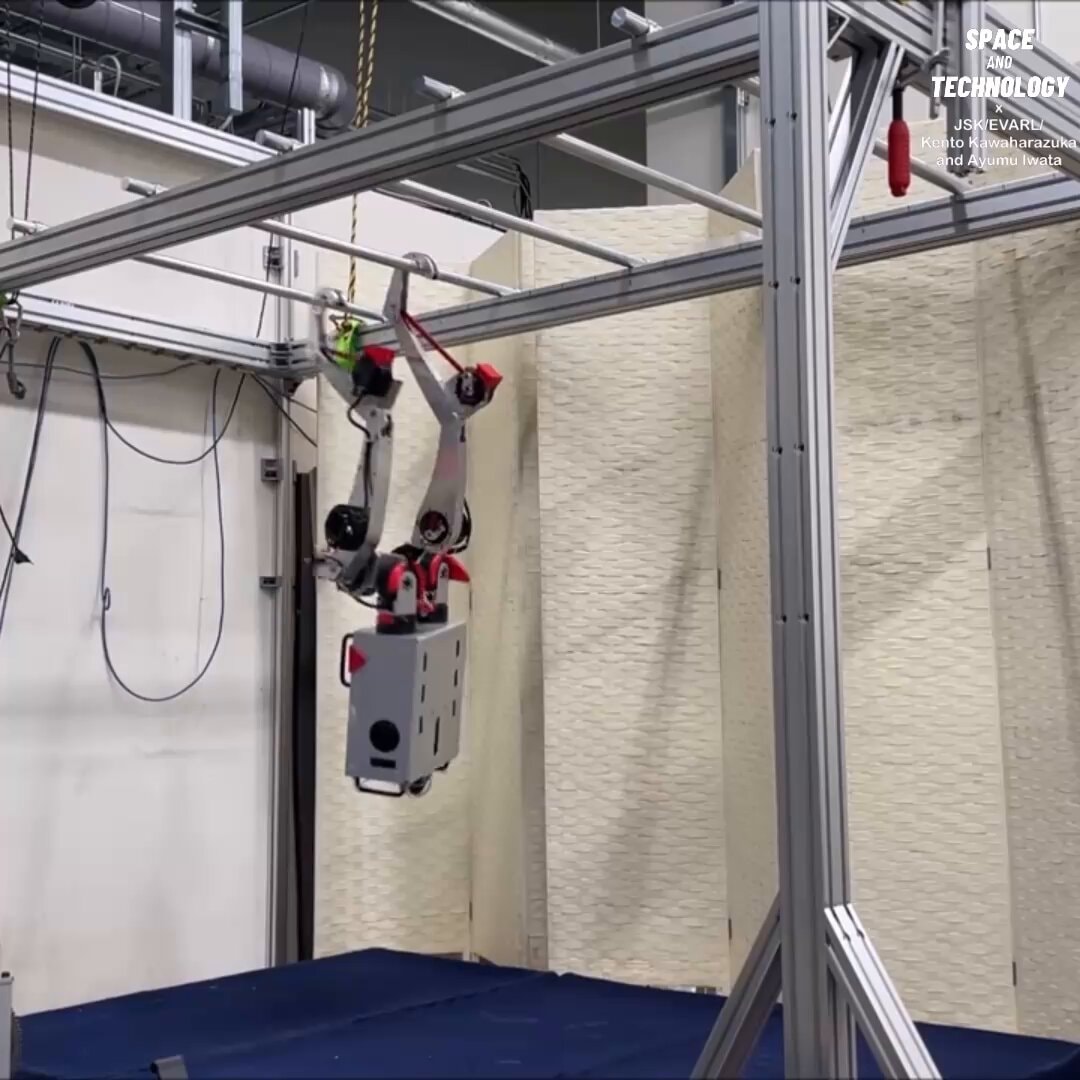
University of Tokyo monkey bar robot
por Terrymiller: University of Tokyo
Researchers at the University of Tokyo built a life-sized dual-arm robot that swings across monkey bars using Waypoint-Guided Reinforcement Learning. This approach teaches complex whole-body movements by guiding the hand through key waypoints. In real-world tests, the robot crossed four bars and recovered from failed grasps by rebuilding its swing to try again. SPACE AND TECHNOLOGY JSK/EVARL credits Kento Kawaharazuka and Ayumu Iwata.
Transcrição (en)
Researchers at the University of Tokyo developed a life-size dual-arm robot that can swing across monkey bars like a primate. The robot uses waypoint-guided reinforcement learning, where researchers provide key points for its hand trajectory, while reinforcement learning learns the coordinated body movements. In simulations, it successfully navigated different monkey bar layouts, including uneven, circular, and up-and-down courses. In real-world testing, the robot crossed four bars continuously and even recovered after missing a rebuilding its swing and trying again.